Physical AI. Cheese Factory.
Camera-guided sorting. Evidence you can explore.
- 01A simulated factory
- 02An operator’s view of every decision
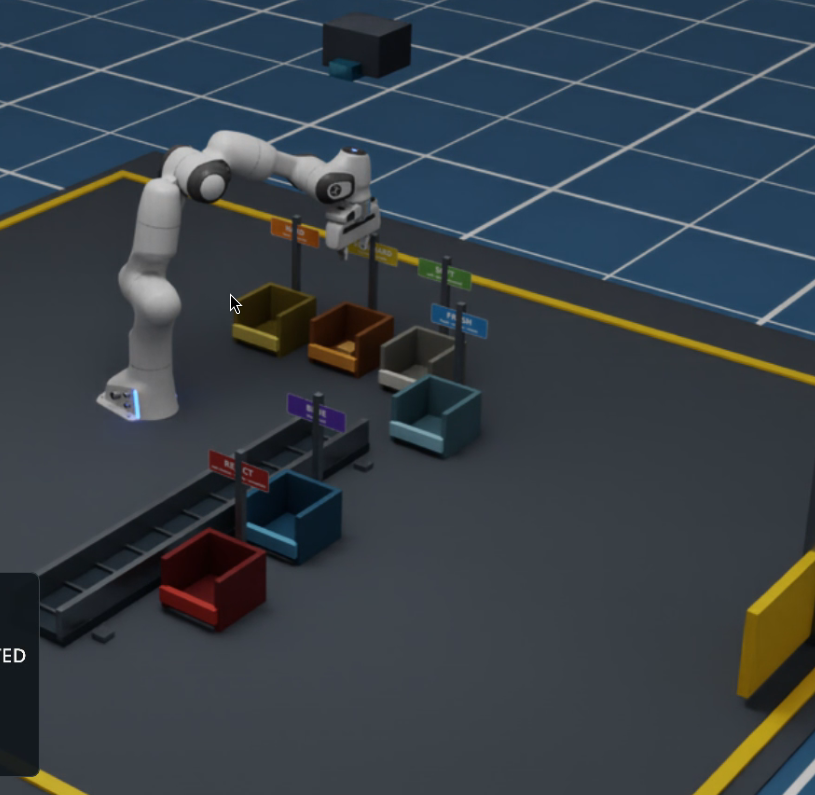
Camera-guided sorting. Evidence you can explore.
Camera-guided sorting. Evidence you can explore.
A clear sorting decision starts with the item in front of the camera.
The decision travels with the image and position that produced it.
Image and position
Cheese type and bin
Item, frame and confidence
Franka motion in Isaac Sim
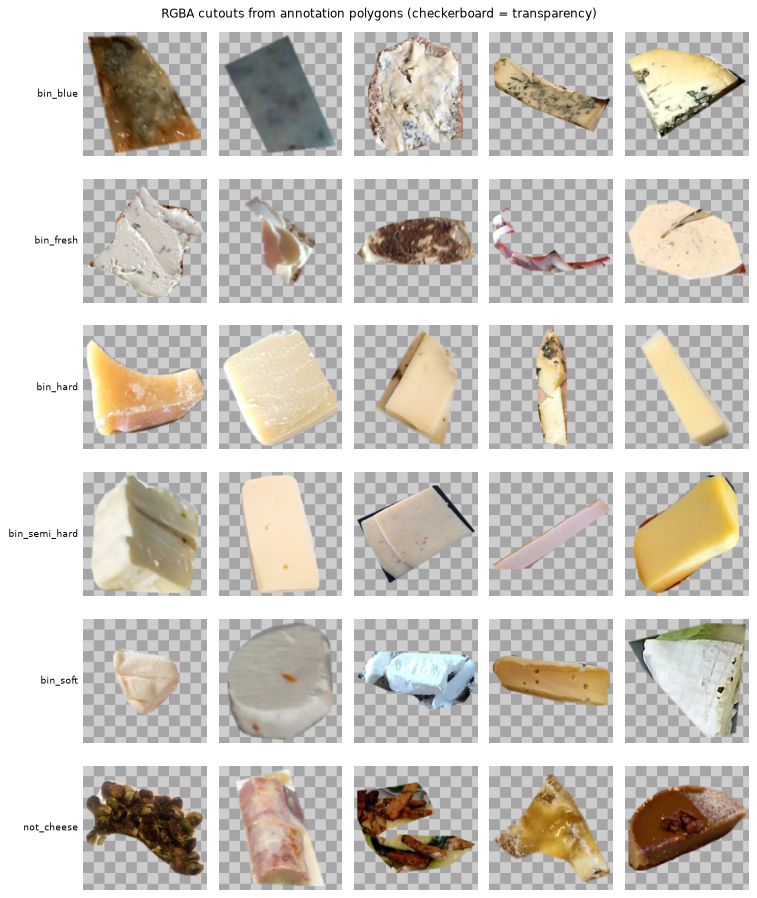
ConvNeXt training in PyTorch, with a 384 px model input.
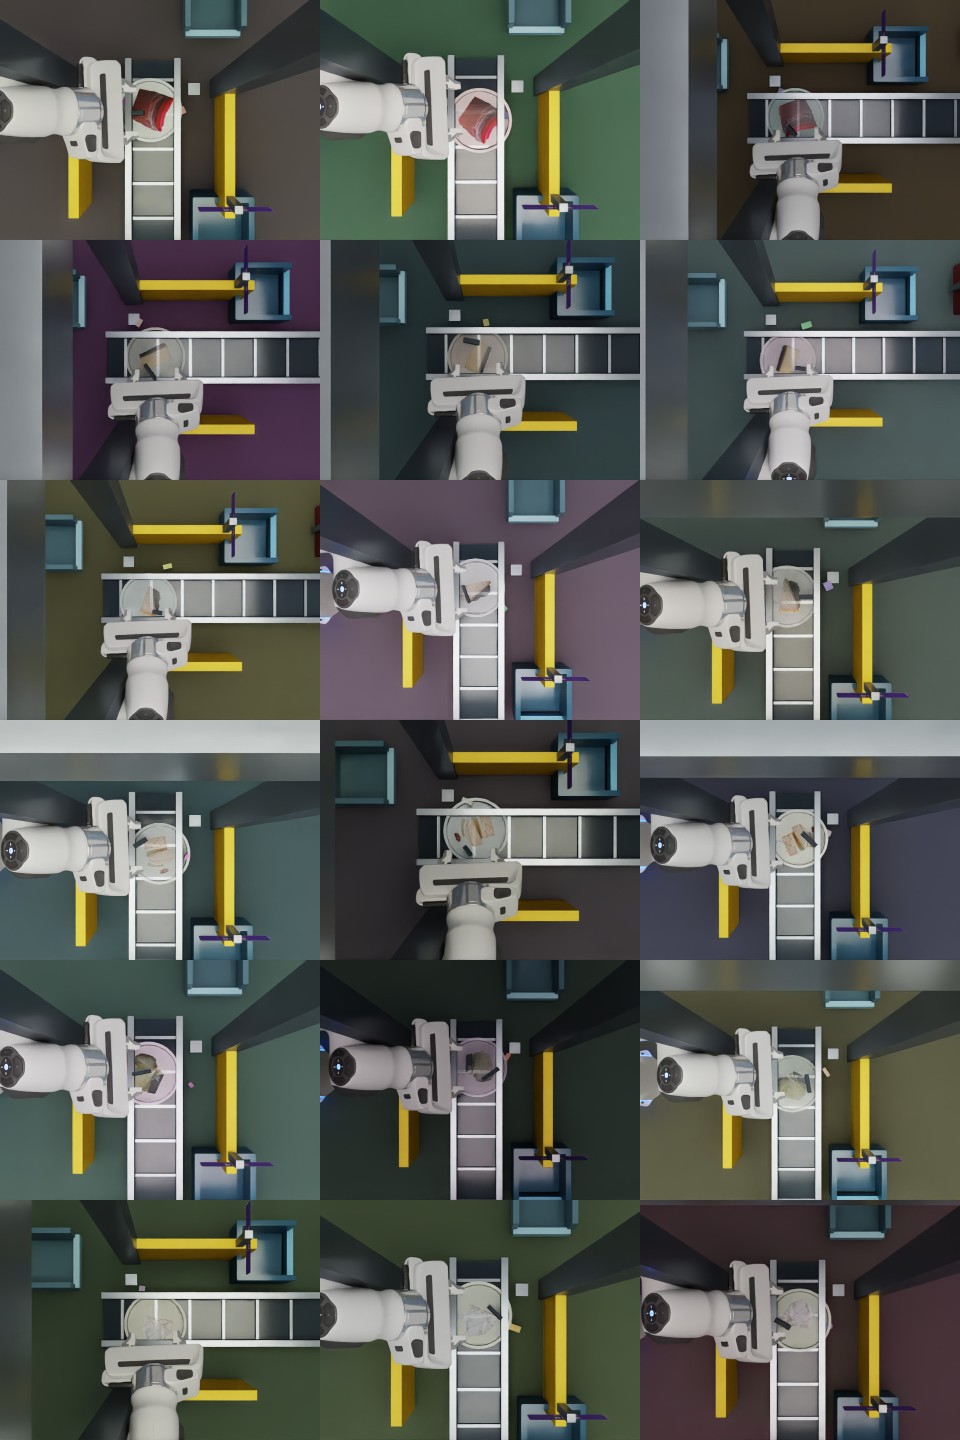
Clearance and collision geometry belong in the task design.
Two model tasks. Two separate image-test sets.
| Model task | Correct images | Accuracy | Macro-F1 |
|---|---|---|---|
| Cheese type | 429 / 545 | 78.7% | 0.4365 |
| Destination bin | 656 / 845 | 77.6% | 0.5509 |
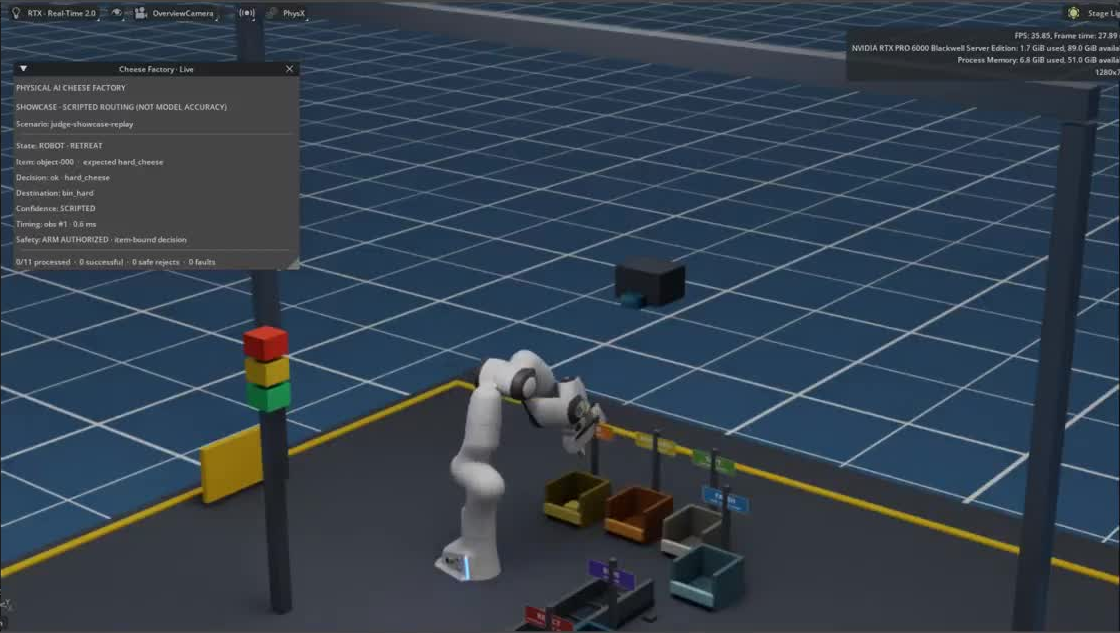
An eleven-item run makes the gap visible.
3 placements + 1 reject
Motion check only
The supplied demonstration, in its own frame.
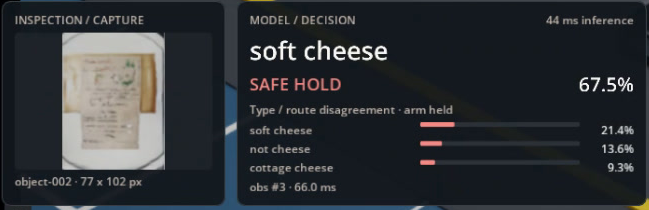
Captured image. Conflicting predictions. A visible hold reason.
Share the scene without asking the viewer to install Isaac.
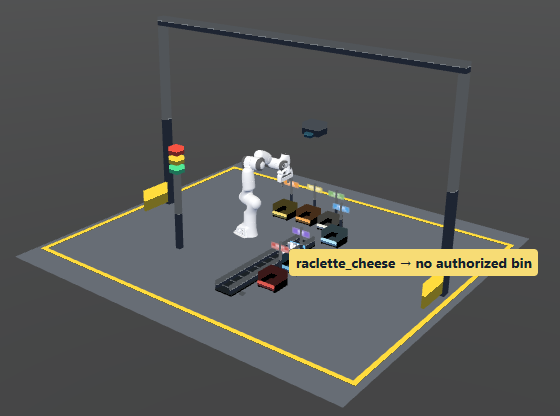
Pause the recording, then explore what matters.
Choose the format that fits the review.
Recorded camera view
Choose playback time
Share a video file
Interactive live session
Operate the simulator
Keep the host running
Recorded 3D scene
Choose time and camera
Publish static files
Isaac Web Exporter packages a scene for another time and viewpoint.
Compatible motion in USD
GLB geometry, motion and JSON
Three.js / WebGL
Pause a pick. Change the view.
Explore the recorded Cheese Factory scene.
A second supplied demonstration.
Bring observations, explanations and reviewed labels into one workspace.
Keep both success and failure available for inspection.
Run and sensor evidence
Grounded explanations
Bounded task outcomes
Reviewed annotation
Run a scenario, inspect its evidence and review a label.
The operator’s conversation stays separate from motor authority.
Evidence and discussion
Authenticated orchestration
Execution authority
A recorded Isaac camera frame accompanies measured robot motion and placement.
The third supplied demonstration.
Let’s explore the evidence together.